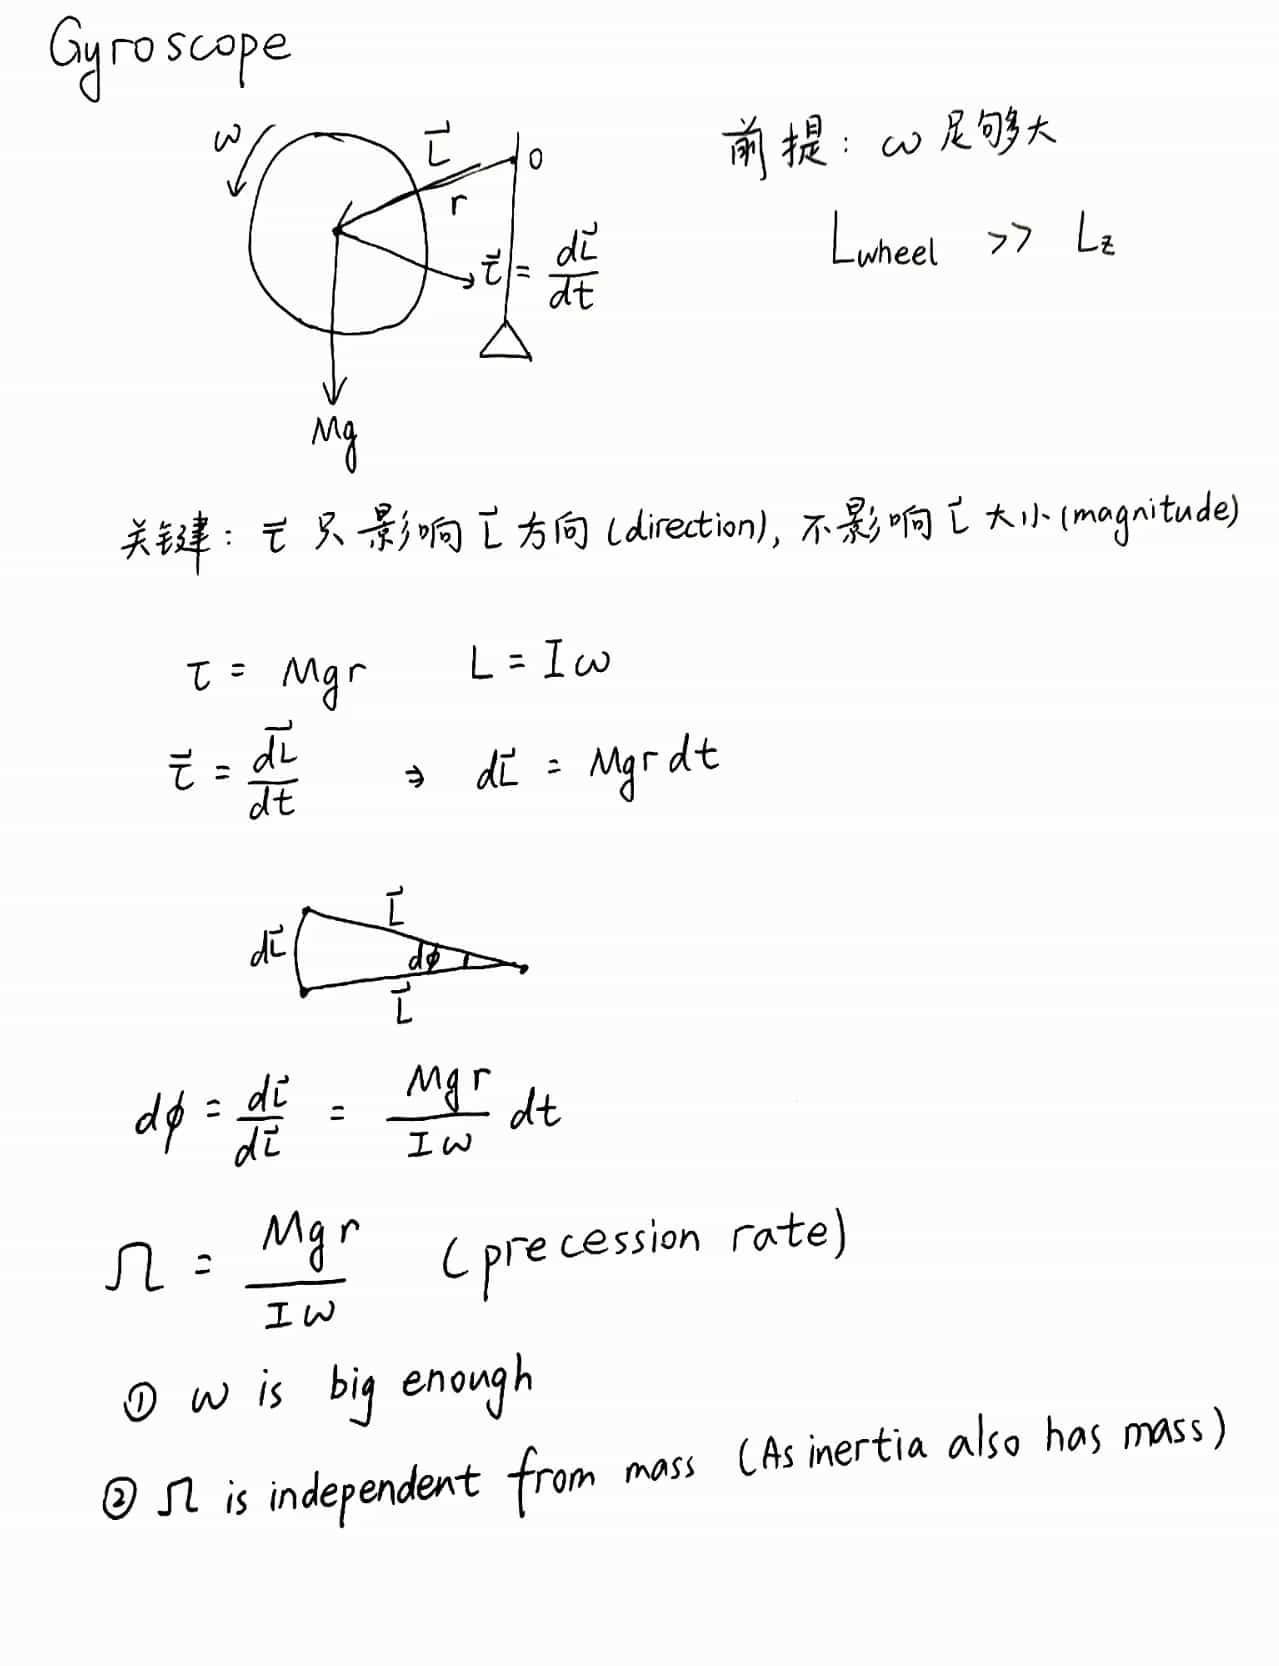
Gyroscope
Gyroscope 1. Premise and Key Insight Premise: The angular velocity ω\omegaω is sufficiently large. The spin angular momentum dominates: Lwheel≫LzL_{\text{wheel}} \gg L_zLwheel≫Lz. Key Insight: The torque τ⃗\vec{\tau}τ only affects the direction of the angular momentum L⃗\vec{L}L, but it does...
dp+线段树+单调栈:ABC480G
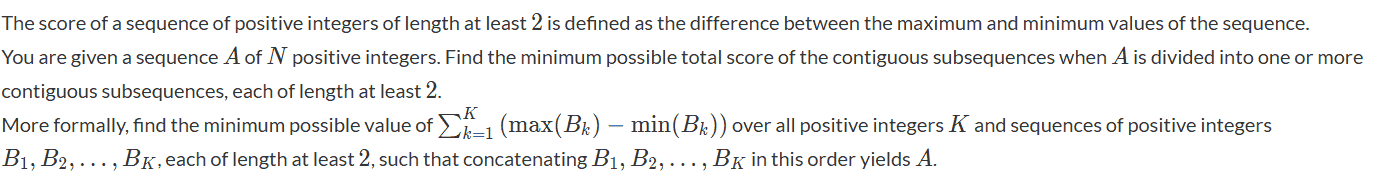
dp+线段树+单调栈:ABC480G G - Zonal Score Minimization 设 fif_ifi 表示前 iii 个数的满足题意的答案 显然有: fi=minj≤i−2(fj+mink∈[j+1,i]ak−maxk∈[j+1,i]ak)f_i=\min_{j\le i -2}(f_j+\min_{k\in[j+1,i]}a_k-\max_{k\in[j+1,i]}a_k) fi=j≤i−2min(fj+k∈[j+1,i]minak−k∈[j+1,i]maxak) 我们考虑拿数据结构来维护。后缀min、max之类的我们可以直接拿单调栈来求,然后拿个...
dp+线段树+单调栈:ABC480G
dp+线段树+单调栈:ABC480G G - Zonal Score Minimization 设 fif_ifi 表示前 iii 个数的满足题意的答案 显然有: fi=minj≤i−1(fj+mink∈[j+1,i]ak−maxk∈[j+1,i]ak)f_i=\min_{j\le i -1}(f_j+\min_{k\in[j+1,i]}a_k-\max_{k\in[j+1,i]}a_k) fi=j≤i−1min(fj+k∈[j+1,i]minak−k∈[j+1,i]maxak) 我们考虑拿数据结构来维护。后缀min、max之类的我们可以直接拿单调栈来求,然后拿个...
杨图计数 + 对角线性质 + 轮廓线计数 + 差分:ICPC2025沈阳H
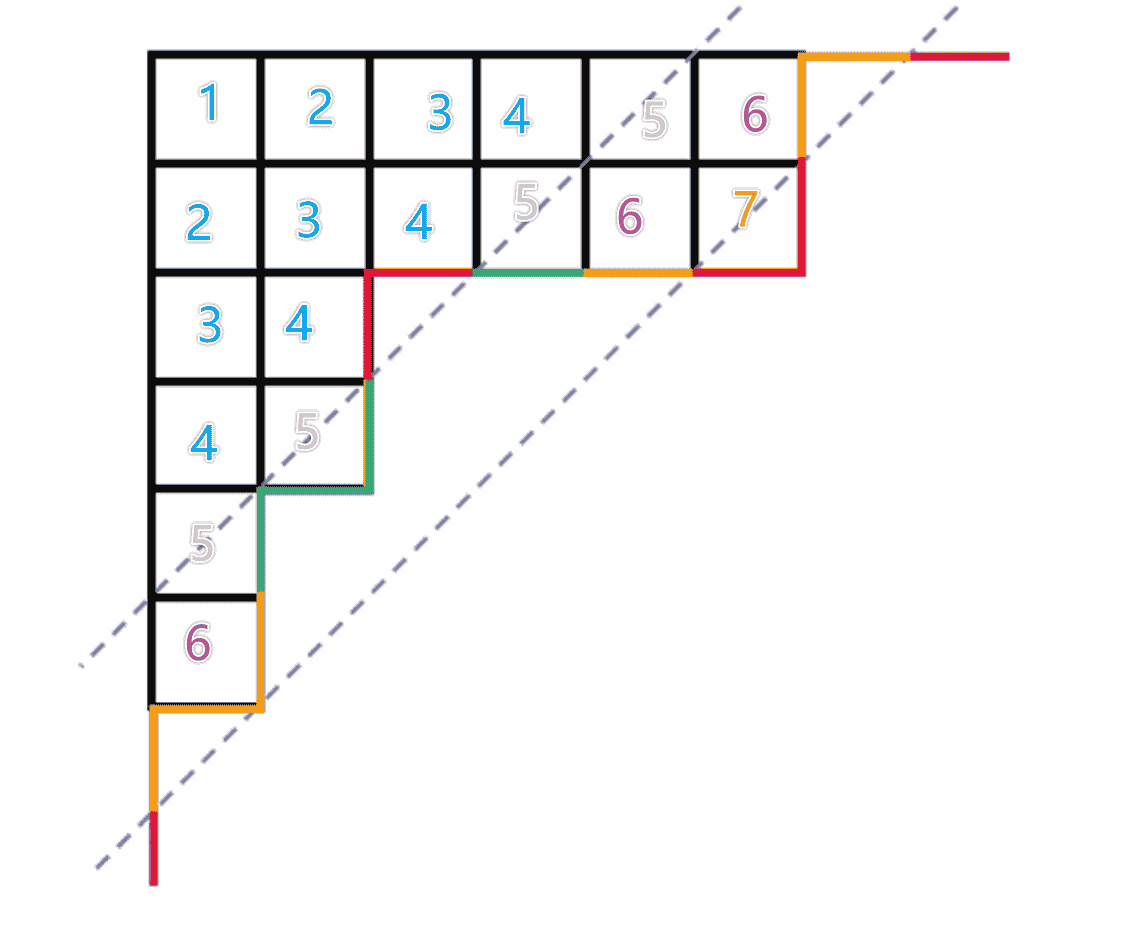
杨图计数 + 对角线性质 + 轮廓线计数 + 差分:ICPC2025沈阳H Cute Young Diagram Counting - Problem - QOJ.ac 我们首先思考一下,翻转操作中,什么是不变的。 假设一个格子在 (i,j)(i,j)(i,j),我们让其贡献到 ti+jt_{i+j}ti+j 里。不难证明,ttt 序列是始终不变的。 ttt 序列的形式必然是:0,1,x,y,⋯ ,z,0,0,⋯0,1,x,y,\cdots,z,0,0,\cdots0,1,x,y,⋯,z,0,0,⋯ 接下来我们证明,所有满足此 ttt 序列的杨图必然是可以构造出来的。 首先,所有操作...
Smooth Rolling
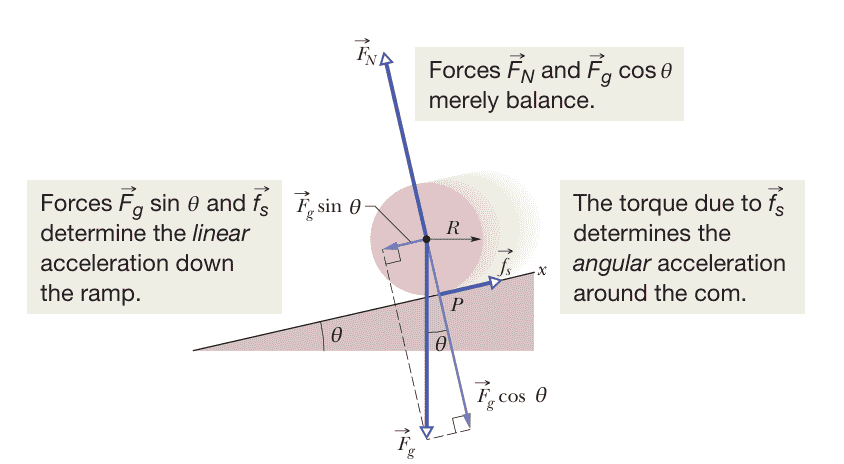
Smooth Rolling Please always note that: The friction is static friction, there is always no work! Important: always remember the direction !!! (both linear and angular) Newton’s Second Law and Motion fs−Mgsinθ=MaRfs=Iαa=αRf_s-Mg\sin\theta = Ma\\ Rf_s=I\alpha\\ a=\alpha R fs−Mgsinθ=MaRfs=Iαa=α...
期望 + dp + 计数 + 策略转限制:ICPC2025沈阳E
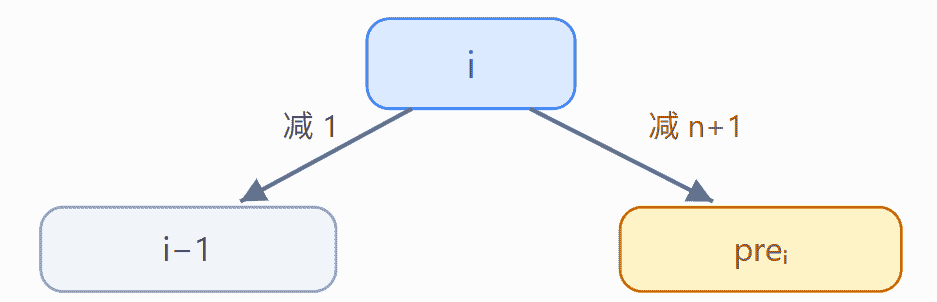
期望 + dp + 计数 + 策略转限制:ICPC2025沈阳E Play It by Ear - Problem - QOJ.ac 令 posxpos_xposx 表示编号为 xxx 的牌在原先牌堆的位置。 设 fif_ifi 表示完成第 iii 步(aia_iai 牌打出),至少需要多少步。设对于 aia_iai 这张牌,上一次出现在 preipre_iprei 的位置,那样子有: fi≥fi−1+1fi≥fprei+n+1f_i\ge f_{i-1}+1\\ f_i\ge f_{pre_i} + n + 1 fi≥fi−1+1fi≥fprei+n+1 因为上一...
Calculus - Limit 做题简记2
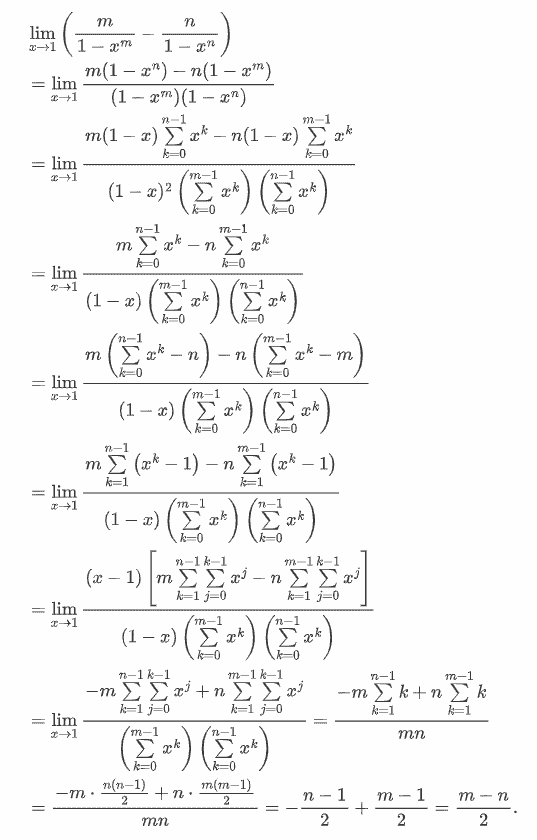
Calculus - Limit 做题简记2 Key Point sufficiently large 的必须转化为:∃N,∀n≥N,...\exist N,\forall n\ge N,...∃N,∀n≥N,...,而不能在前面直接使用 Let ε=l\varepsilon = lε=l 中,一定要判断这些 lll 是否大于0 T1 : Induction to Prove Monotonic 2.30 xn=α+xn−1x_n=\sqrt{\alpha+x_{n-1}} xn=α+xn−1 证明 xn{x_n}xn monotonic increasing 这种证明很...
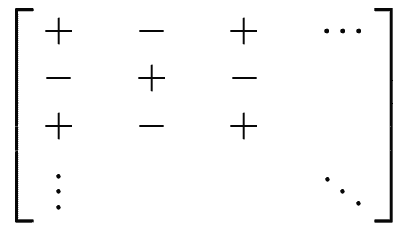
Linear Algebra - Chapter 3 Determinants
Linear Algebra - Chapter 3 Determinants Section 3.1 Introduction to Determinants Definition: For n=2n = 2n=2 : detA=a11a22−a12a21\det A = a_{11}a_{22}-a_{12}a_{21}detA=a11a22−a12a21 For n≥2n \ge 2n≥2, we have a recursive definition: detA=∑j=1n(−1)i+ja1jdetA1j\det A=\sum_{j=1}^n(-1)^{i+...
Rotation and Rolling
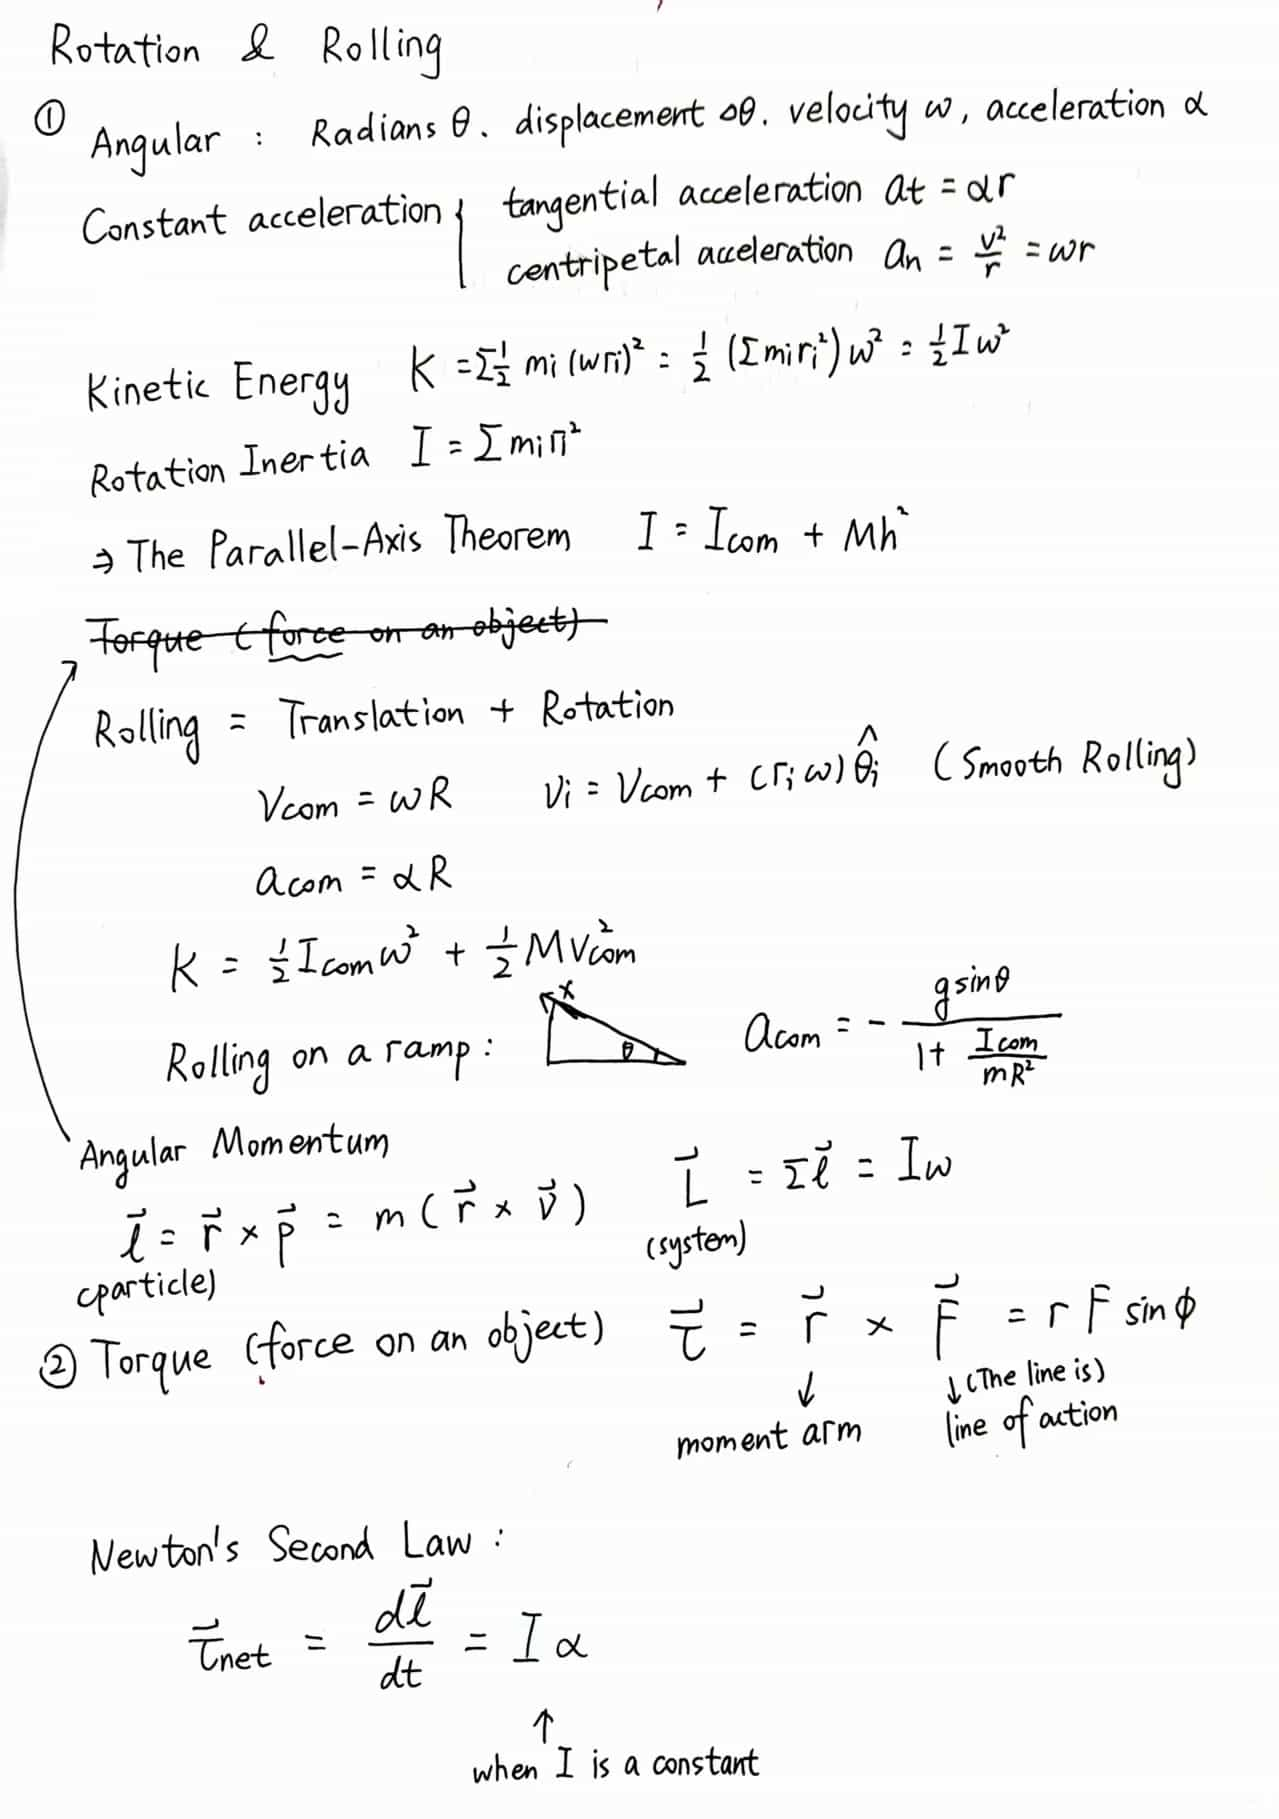
Rotation and Rolling Angular Kinematics Angular Variables: Radians: θ\thetaθ Displacement: Δθ\Delta\thetaΔθ Velocity: ω\omegaω Acceleration: α\alphaα Constant Acceleration For an object undergoing constant angular acceleration, the linear accelerations are: Tangential acceleration: at=αra...
推性质 + 绝对值函数处理:ABC479G
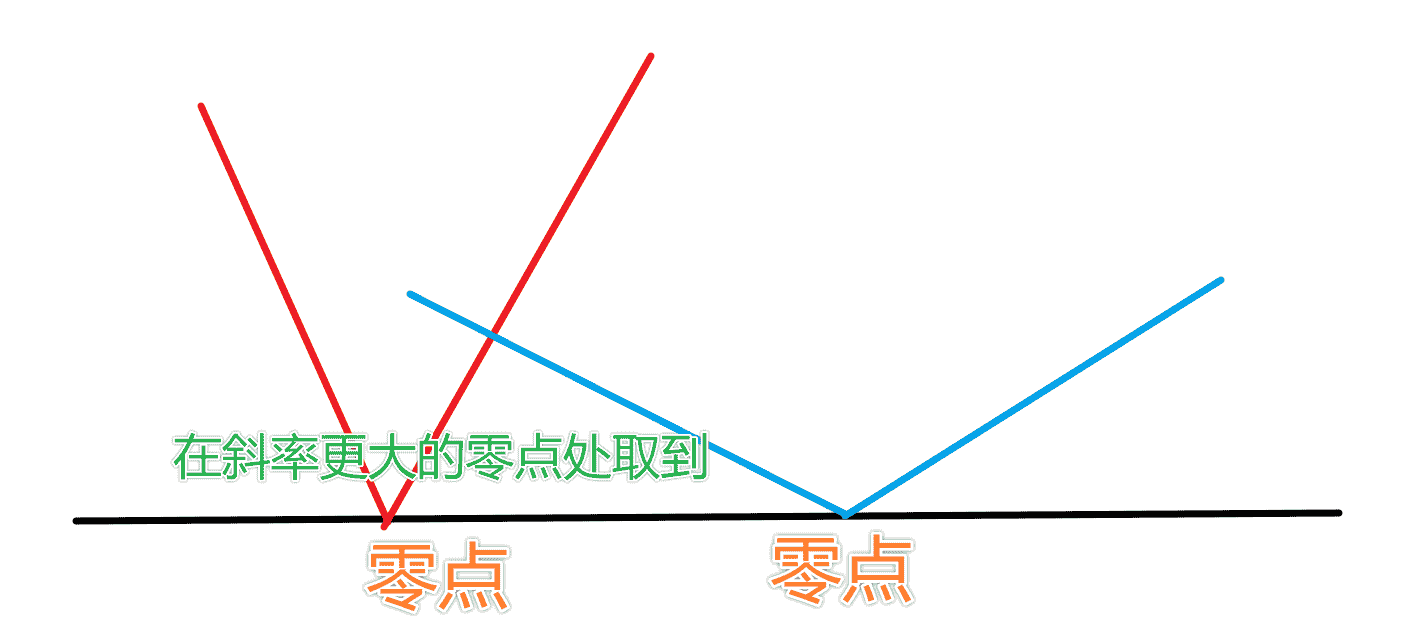
推性质 + 绝对值函数处理:ABC479G 题目给定的式子是: (Ai+ci)(Bj+dj)=(Aj+cj)(Bi+di)(A_i+c_i)(B_j+d_j)=(A_j+c_j)(B_i+d_i) (Ai+ci)(Bj+dj)=(Aj+cj)(Bi+di) 先除过去: Ai+ciBi+di=Aj+cjBj+dj\frac {A_i+c_i}{B_i + d_i}=\frac {A_j+c_j}{B_j+d_j} Bi+diAi+ci=Bj+djAj+cj 设上式为一个定值 pq\dfrac p qqp Ai+ciBi+di=pq\frac {A_i+...